
XLeRobot
Price on request
Ask for a quote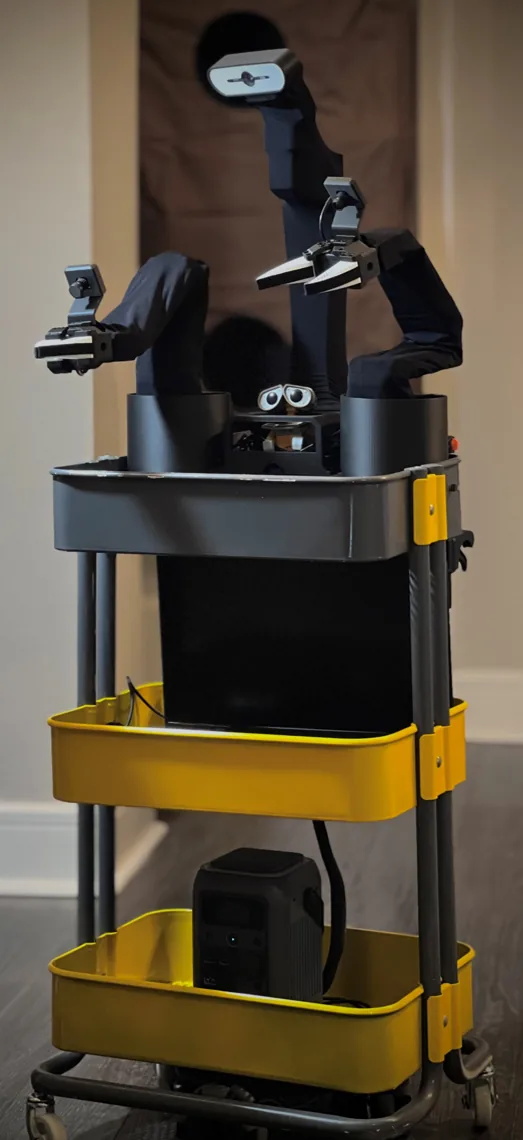
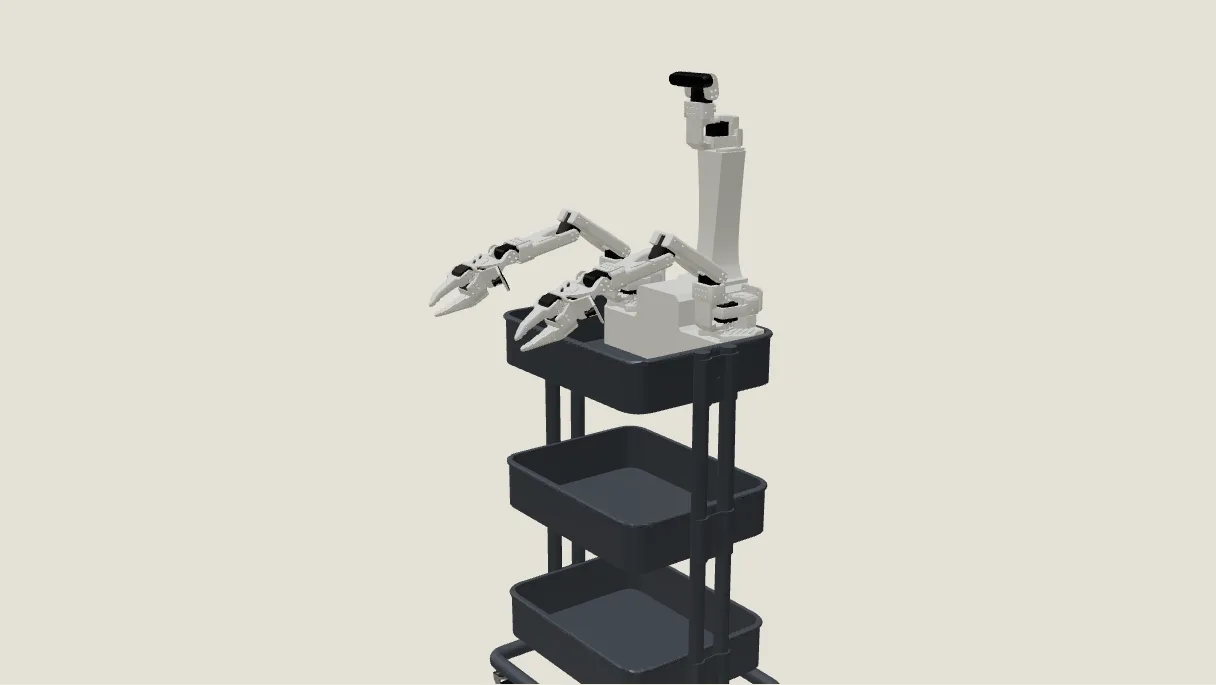
Photos and 3D model: XLeRobot project (github.com/Vector-Wangel/XLeRobot), Apache-2.0.
XLeRobot puts two SO-101 arms, a camera head and a wheeled base on an IKEA RÅSKOG cart. It runs on the LeRobot stack, so anything you learn on a tabletop SO-101 carries over.
It is a research and teaching platform, not a finished consumer robot. Expect to write Python. In return you get a mobile manipulator for a fraction of the usual price, with open hardware, URDFs and a simulator.
We can supply the kit, assemble and calibrate it, and get your first dataset recorded. The IKEA cart, battery and Raspberry Pi are sourced separately.
- Made by
- XLeRobot open-source project (kit by WowRobo)
- Category
- Dual-arm mobile robot
- For
- University labs, Robotics & AI startups, Experienced makers
- Price
- On requestIt depends on the kit version, import costs and whether you want it assembled.
Features
What XLeRobot does
- Two arms, one base
- Two 6-joint SO-101 arms with grippers, a 2-servo camera head and a mobile base.
- Many ways to drive it
- Keyboard, Xbox or Switch Joy-Con controllers, SO-101 leader arms, or a Meta Quest headset.
- Built on LeRobot
- Record datasets in the LeRobot format and train ACT or SmolVLA. Community recipes exist for pi0.5.
- Open source (Apache-2.0)
- 3D models, URDFs, bill of materials and code are all public. You can repair and modify everything.
3D model
The whole robot, in 3D
Specifications
- Arms
- 2 × SO-101, 6 joints each incl. gripper
- Actuators
- Feetech STS3215 12 V servos
- Head
- 2-servo camera head
- Cameras
- 2 wrist + 1 head (RealSense optional)
- Reach
- ≈ 40 cm per arm
- Payload
- ≈ 0.6–1 kg per arm
- Workspace height
- ≈ 0.5–1.25 m from the floor
- Compute
- Your laptop/PC; Raspberry Pi 5 optional
- Power
- Portable power station over USB-C (≈ 180 W max draw)
- Software
- Hugging Face LeRobot, ManiSkill sim, Python
- Licence
- Apache-2.0
In the box
| Item | Qty |
|---|---|
| SO-101 follower arms, assembled (12 V servos) | 2 |
| Base expansion: 4 servos, 2 drive wheels, printed parts and fasteners | — |
| 2 MP camera modules | 3 |
| 12 V power supplies | 2 |
Not included: IKEA cart, battery, Raspberry Pi, RealSense
Use
Where it gets used
Use cases
- Imitation learning and VLA research
- Collecting teleoperation datasets
- University robotics courses
- Prototyping home and service robot tasks
Upstream docs and source
- XLeRobot on GitHubgithub.com
- XLeRobot docsxlerobot.readthedocs.io
From us
What we add to the hardware
- Assembly and calibration
- We can build, calibrate and test robot arms and mobile robots before they reach you.
- Classes and workshops
- We have taught robot basics to vocational students and run a primary-school robotics club. We can do the same for your school or team.
- Support in Thai
- Questions, spare parts and repairs, handled by the engineers who sold it to you.
- Custom software
- Need the robot to do something specific? We are a software house too.
Also from GSF
Other products
 STEM robot kitsMakerzoidBuild a robot from bricks, then code it from a phone.From ฿2,400
 Online robotics learning platformRoboParkLearn to program robots in an online simulator, no hardware needed.In development
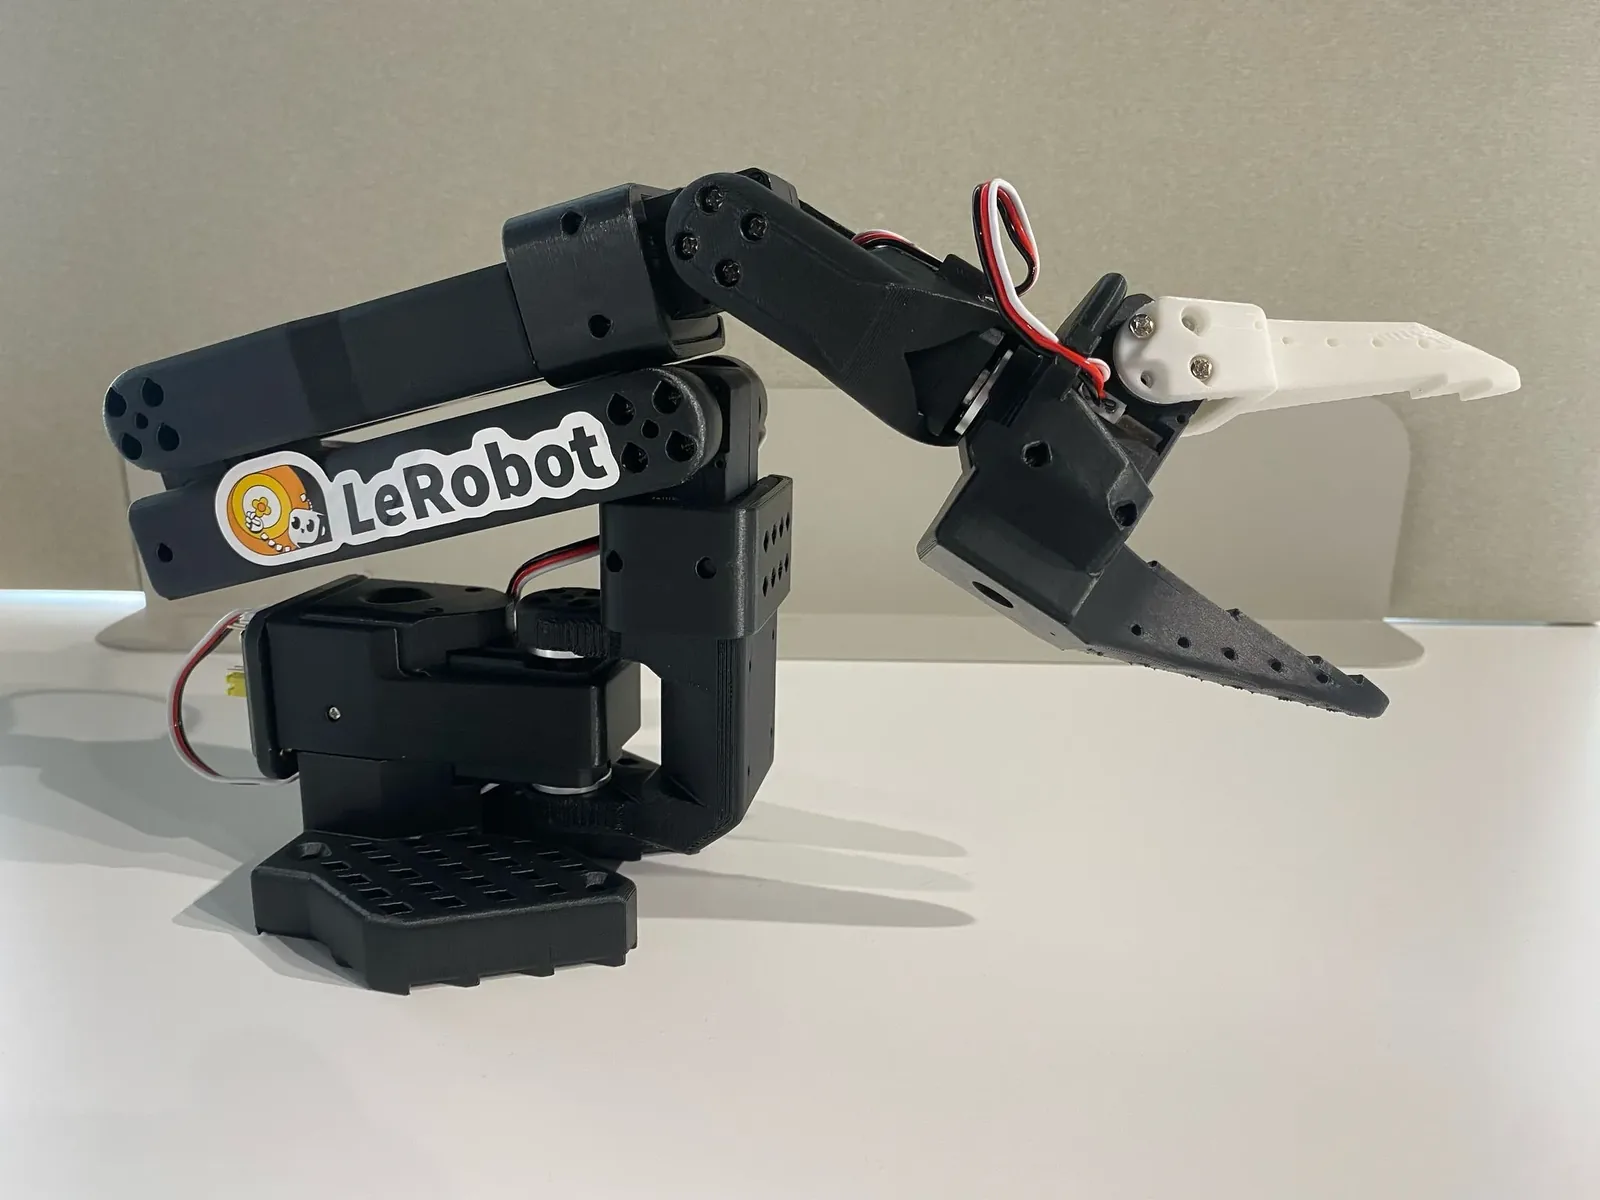 Robot arm kitLeRobot SO-101Move one arm by hand and the other copies you. Then it learns the task.Price on request
- Project management toolTakticA project management tool for teams.In development
Ask about XLeRobot price and lead time
Tell us what you want to use it for and whether you want it assembled. We reply with a price and a delivery estimate.
- Office
- 52/9 Suchawadee Village, Moo 3, Soi Sukhaprachasan 3Tiwanon Road, Bang PhutPak Kret, Nonthaburi 11120Open in Google Maps
- Hours
- Mon–Fri, 9:00–18:00 (Bangkok time)